
Michelle Sun
@michellelsun
Physical AI value chain, Robotics, Industrial Automation
865 Following 13K Followers
The next wave of generational companies will come from manufacturing AI.
There is so much to build, from the materials going into a factory to the finished products coming out.
Let's map out the 5 layers of manufacturing, with incumbents and startups:
• Materials and standard items: the metal, resins and fasteners that production starts with.
• Parts: turning those inputs into a housing, bracket or cover made to a design.
• Components: making the motors, sensors, chips and batteries that give a product its capabilities.
• Subassemblies: bringing parts and components together into something like a battery pack or wire harness.
• Finished products: delivering the robot, vehicle or appliance to the customer.
The opportunity looks different at each layer. Where could AI help a team make a better part, get production running sooner or learn faster from a failed run?
Which layer are you building in?
The map comes from the latest Core Matter (@corematter_) piece, “Can America Leapfrog Shenzhen?”
@standardbots @Figure_robot @Senra_Systems @westmagco @atlasmotion @sendcutsend @MachinaLabs_ @noxmetals @agilityrobotics @1x_tech @HadrianInc @Tesla
Show more

What does it take to build one robot actuator?
We mapped it from the mine to the supplier.
- 52 named suppliers, sourced from filings and company disclosures
- 66 parts, processes and materials across 9 stages
- Rare-earth magnets: 8 named makers and the refining chain behind them
- Steel connects to 48 items in the map
- One ring gear traced to the machine that cut it
Click any part to see what it depends on.
Hit “Simulate a shortage” to watch it spread.
This is v0.1. We add suppliers as each one is sourced.
Explore the interactive page in the comment, and please share any feedback !
Follow @CoreMatter_ for physical AI deep dives.
Show more

I’ll be at IROS this week and look forward to connecting with researchers and operators building dexterous hands, autonomous factories, world models.
Core Matter @corematter_ is co-hosting Robotics Research Night with Saturday Robotics @saturdayrobotic on Monday 9/28. Come join us for an evening of research discussions. Big thanks to our sponsors @FAIRplus_sz and Daimon Robotics.
Come join us!
Sign up here:
==
@junfanzhu98 @aurorafeng_01
Show more


🛫 I’m heading to Pittsburgh for IROS 2026 🤖 9/27–10/2. Introducing
🥂 @saturdayrobotic × #IROS2026#: Saturday Robotics Research Night
📍 Pittsburgh | Sept 28, 5:30–9:30 PM
🎟️ RSVP:
Lightning talks from researchers at @Caltech, @RhodaAI , @XSquareRobot, @CAS__Science, @UCBerkeley, and @HarryXu12 (@PokeBot_Global), covering:
• humanoid safety + RL
• in-context learning for robot data
• scalable sim evaluation
• 3D VLA + memory + inference-time learning
• hindsight reward editing
• GPT-6 Astra & the future of robotics
The interesting part isn’t just the demos.
It’s figuring out what actually scales—and what doesn’t.
A few questions to discuss at Saturday Robotics IROS research night:
→ Is robot scaling really about more data—or better experience per sample?
→ Can in-context learning turn robot data from static demonstrations into reusable experience?
→ Will world models become the data engine for robotics?
→ What should robots remember over long horizons?
→ And what does scaling not fix—representation, architecture, reward, evaluation?
If you’re working on robot foundation models, world models, in-context learning, robot data, sim2real / Real2Sim2Real—or just trying to answer “how do we actually scale robot learning?”—let’s grab coffee ☕️.
See you in Pittsburgh. 👋 @aurorafeng_01 @michellelsun
Show more


China's actuator supply base is being built by companies arriving from 5 overlapping industrial backgrounds:
1/ Reducer and motion specialists extending their core gearbox technology.
2/ Precision-transmission companies adding actuators, joint modules, motors, drives or roller screws.
3/ Joint-module vendors packaging motors, reducers, encoders and drives into integrated products.
4/ Automotive suppliers expanding into linear and rotary robot actuators.
5/ Linear-motion companies entering through planetary roller screws.
The starting point matters because it shapes where each company may have an advantage: precision gearing, module integration, automotive production or linear motion.
This map tracks 18 companies and preserves the stage each has disclosed.
Show more

.@Meta's 'one more thing' last night was the Muse Charm:
- a palm-sized AI holdable with a 2-inch OLED display, front and rear cameras, a built-in 5G modem.
- no WiFi needed, no phone tether
- push to talk using finger print
What I find most interesting is the use of the cameras. The cameras are more for Muse's continuous visual context for analysis and action, photo/video capture is secondary.
So, cameras are acting as the "eyes" for Muse first, and cameras for the user second.
That's a meaningful packaging decision for embodied perception. The Charm turns @muse into the always available agent, with eyes, ears and a 5G backhaul.
Show more


Amazing write up by David
My favorite was the anecdote 'Alibaba does a “worst product” award every year at all hands.'
It is such a great illustration of how American and Chinese education and culture differ
Show more
.@SkildAI ‘s S1 practiced soccer against increasingly capable versions of itself in simulation. The robot can now play against a human.
It’s an exciting glimpse of how robots might build on their existing skills
Congrats @deepakpathak and Skild team on another milestone !
Show more

We trained a robot to play football.
How? Self-play for 140 years in a virtual World Cup.
Meet the #Messinator#:

General world models could overtake specialized vision-language-action models around 2027.
@1x_tech founder @BerntBornich made this specific prediction in his interview with @ti_morse
Key highlights:
1. Data diversity is the constraint.
More recordings of the same tasks add less than exposure to new environments, objects, and ways tasks fail. In Bernt’s words, robotics is “diversity bound.”
2. Internet video could do most of the training.
Bernt expects it to provide roughly 99% of 1X’s training data. First-person human video, simulation, teleoperation, and robot experience would supply other kinds of examples.
3. The model should eventually collect its own training data. Bernt wants deployed robots to attempt unfamiliar tasks, record successes and failures, and improve through retraining without a human operating each attempt.
4. That gives the 50,000 target a second purpose.
1X aims to manufacture and ship 50,000 NEOs in 2027. A fleet that size could expose the model to far more variation, provided the robots meet the safety and quality bar for deployment.
Interview:
Show more
can someone older than 22 attend this? asking for a friend
@eriktorenberg @gaganbiyani


How @UnitreeRobotics newest Dex5-S compares with other Dexterous hands in the market
- Pricing
- Detailed specs


22-motor, 22-DOF hand at $6500
How does @UnitreeRobotics's Dex5-S hand compare with the @wuji_global Hand 2 and @SharpaRobotics SharpaWave?
Unitree vs. Wuji vs. Sharpa
- All 3 hands put one motor on each degree of freedom: 22, 20, 22
- All 3 hands are backdrivable
- Prices: $6500, $19500, $50,000
- Price per motor: $295, $975, $2270
Which one would you buy?
Show more

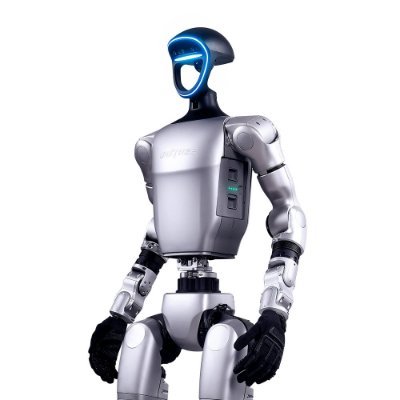
Unitree Introducing: Unitree Dex5-S Dexterous Hand 22 Degrees of Freedom 1:1 Real-Hand Size👋
Precision biomimetic dexterous hand, price from $6.5K (Tax and Shipping cost excluded), with all 22 joints supporting smooth backdrivability, and each joint equipped with limit impact torque protection.
Show more

Scott Walter, Robotics Research Diligence Director at RoboStrategy ($BOT), wants a humanoid decathlon.
“I'm throwing down the gauntlet for the humanoid decathlon challenge.”
One robot. The same 10 human events. The same rules.
That means more than a sprint demo:
› Hurdles and turns
› A pole vault that tests upper-body and grip strength
› A baton exchange that demands manipulation
› A long-jump sand pit, because sand in the joints is part of the test
A specialized robot can win one optimized event. A decathlon asks which joints, control policies, and hands survive across a body of work.
@GoingBallistic5 @RoboStrategy
Show more


While we do a quick survey of the main hand designs on the market, it is primarily used to contrast three designs less talked about. I appreciate Michelle coming up with the idea to discuss Allonic, Daxo and Tacta.
Show more
Inside RoboStrategy $BOT's robotics research with Scott Walter, PhD @GoingBallistic5
Tesla, Figure and the robot hand fight.
“If they exist, where are they?”
Scott breaks down Tesla Optimus (@Tesla_Optimus), Figure (@Figure_robot), 1X (@1X_tech), Wuji (@Wuji_global) and Sharpa Wave (@SharpaRobotics), then goes to the design extremes:
a braided hand, up to 120 tendons, and a hydraulic manipulation system built outside the humanoid.
“They both have their pros and cons. They both have the big engineering challenges in what they're trying to do.”
We cover:
› Tesla and Figure's opposing paths through tendons
› Why a wrist makes cable routing much harder
› @AllonicRobotics, @DaxoRobotics and @TactaSystems at the design extremes
› A decathlon for humanoids
› Why robot runners may stop looking human
› General-purpose bodies and specialized workers
TIMESTAMPS
00:00 The labor prize and the 5-year forecast
00:24 The Fermi paradox of robotic hands
01:18 Tesla, Figure and the tendon debate
05:10 Bowden tubes and wrist routing
11:15 Joints, actuators and real control
14:38 Why the pinky matters
17:23 Humanoid Games as engineering experiments
21:57 The humanoid decathlon challenge
26:28 Tesla's abandoned hand iterations
27:55 Wuji and Sharpa Wave
38:29 Three extreme hand designs
38:53 Allonic's braided structure
51:15 Daxo and up to 120 tendons
01:02:36 Tacta's worker data
01:05:18 A hand system outside the humanoid
01:13:12 Data-center cable insertion
01:16:22 General bodies, specialized work
01:19:18 Why this 5-year forecast may be different
Show more

Inside RoboStrategy $BOT's robotics research with Scott Walter, PhD @GoingBallistic5
Tesla, Figure and the robot hand fight.
“If they exist, where are they?”
Scott breaks down Tesla Optimus (@Tesla_Optimus), Figure (@Figure_robot), 1X (@1X_tech), Wuji (@Wuji_global) and Sharpa Wave (@SharpaRobotics), then goes to the design extremes:
a braided hand, up to 120 tendons, and a hydraulic manipulation system built outside the humanoid.
“They both have their pros and cons. They both have the big engineering challenges in what they're trying to do.”
We cover:
› Tesla and Figure's opposing paths through tendons
› Why a wrist makes cable routing much harder
› @AllonicRobotics, @DaxoRobotics and @TactaSystems at the design extremes
› A decathlon for humanoids
› Why robot runners may stop looking human
› General-purpose bodies and specialized workers
TIMESTAMPS
00:00 The labor prize and the 5-year forecast
00:24 The Fermi paradox of robotic hands
01:18 Tesla, Figure and the tendon debate
05:10 Bowden tubes and wrist routing
11:15 Joints, actuators and real control
14:38 Why the pinky matters
17:23 Humanoid Games as engineering experiments
21:57 The humanoid decathlon challenge
26:28 Tesla's abandoned hand iterations
27:55 Wuji and Sharpa Wave
38:29 Three extreme hand designs
38:53 Allonic's braided structure
51:15 Daxo and up to 120 tendons
01:02:36 Tacta's worker data
01:05:18 A hand system outside the humanoid
01:13:12 Data-center cable insertion
01:16:22 General bodies, specialized work
01:19:18 Why this 5-year forecast may be different
Show more
Foundation world model that can control robots, drive cars, and play video games.
I tried Odyssey's earlier model a few months ago and was impressed how well the video generates from a prompt. This is an exciting milestone.
Congratulations @olivercameron @jeffrey_hawke @odysseyml team!
Show more

Today we’re unveiling Odyssey-3, a big step forward for foundation world models.
It can control robots, power humanoids, drive cars (on the roads of India!), train AIs, pilot drones, and even play video games.
We can’t wait to see what intelligent systems it enables.
Show more


Is Astra the ChatGPT moment for Robotics? A few insights:
1) Strong in-context learning
In 3 tries, it went from learning the controls and understanding the environment to accomplishing a task.
The model reasons through its mistakes; notice the change in grip angle and carry height. It's slow (more on this later) but it's clearly understanding the controls and the space in which it's interacting. 🧵(1/5)
Show more

A weekend exercise for learning robotics: pick one component and explain what goes into it, what comes out, and what changes if you remove it.
Then follow the connection to the next component.
How far can you get before you need to look something up?
Show more











